Grip on slopes
Consider anti-slip behavior and stable movement across uneven, hilly ground.
An agricultural robot concept for mechanized farming on hilly terrain — shaped around useful farm tasks, traction, and accessible operation.
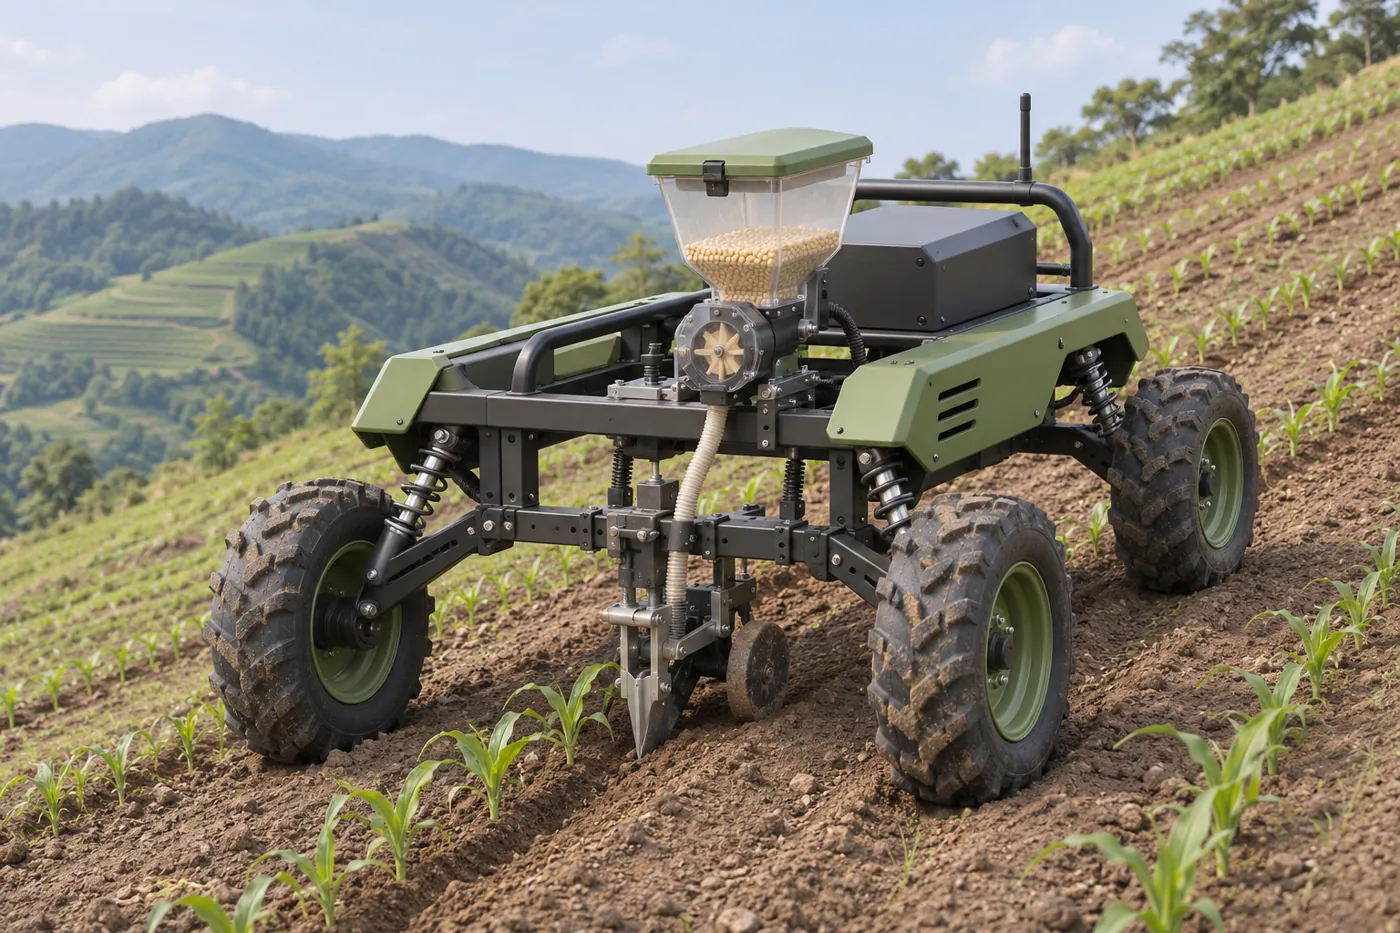
For the Agrobot Design Innovation Challenge, our IIT Madras team developed a concept for cost-effective, eco-friendly, easy-to-operate mechanized farming on hilly terrain.
The robot concept focused on core agricultural tasks: seed metering, transplantation, and weed removal. We also worked on robot behavior, simulations, and semi-autonomous driving, with anti-slip movement over sloping terrain as a key consideration.
The team represented IIT Madras at Inter IIT Tech Meet 9.0 in 2021 and earned a bronze medal.
Consider anti-slip behavior and stable movement across uneven, hilly ground.
Explore mechanisms for metering seeds, transplanting, and removing weeds.
Frame the concept around a cost-effective, eco-friendly, easy-to-operate system.
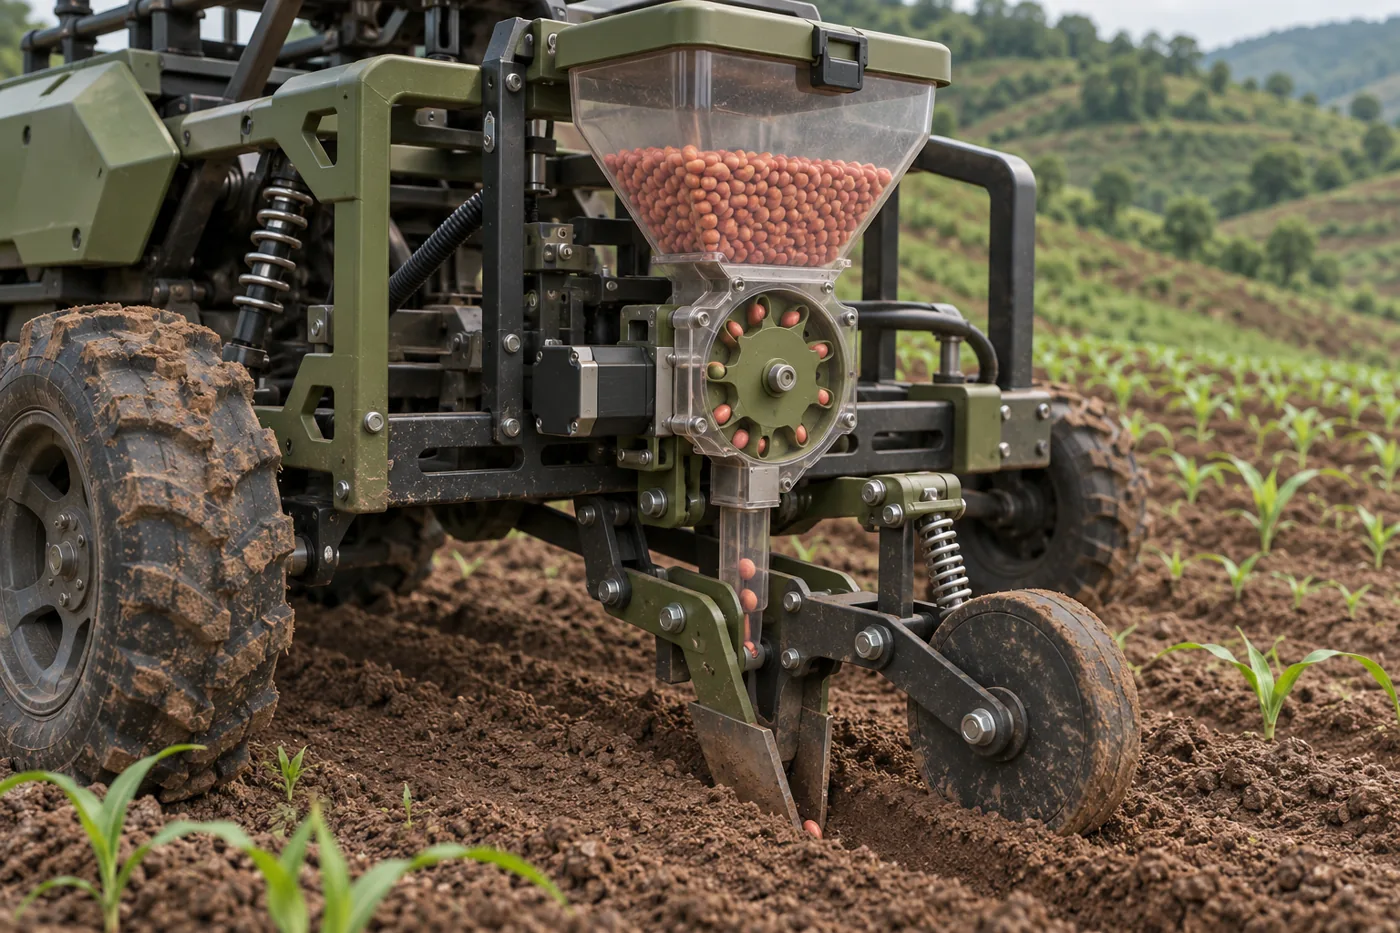
These are concept illustrations created for this portfolio page; they are not photographs or CAD exports of the original competition prototype.